Hardware.
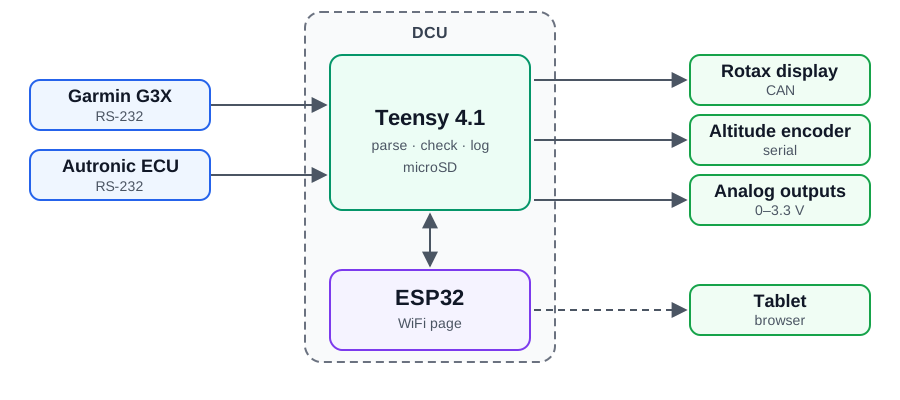
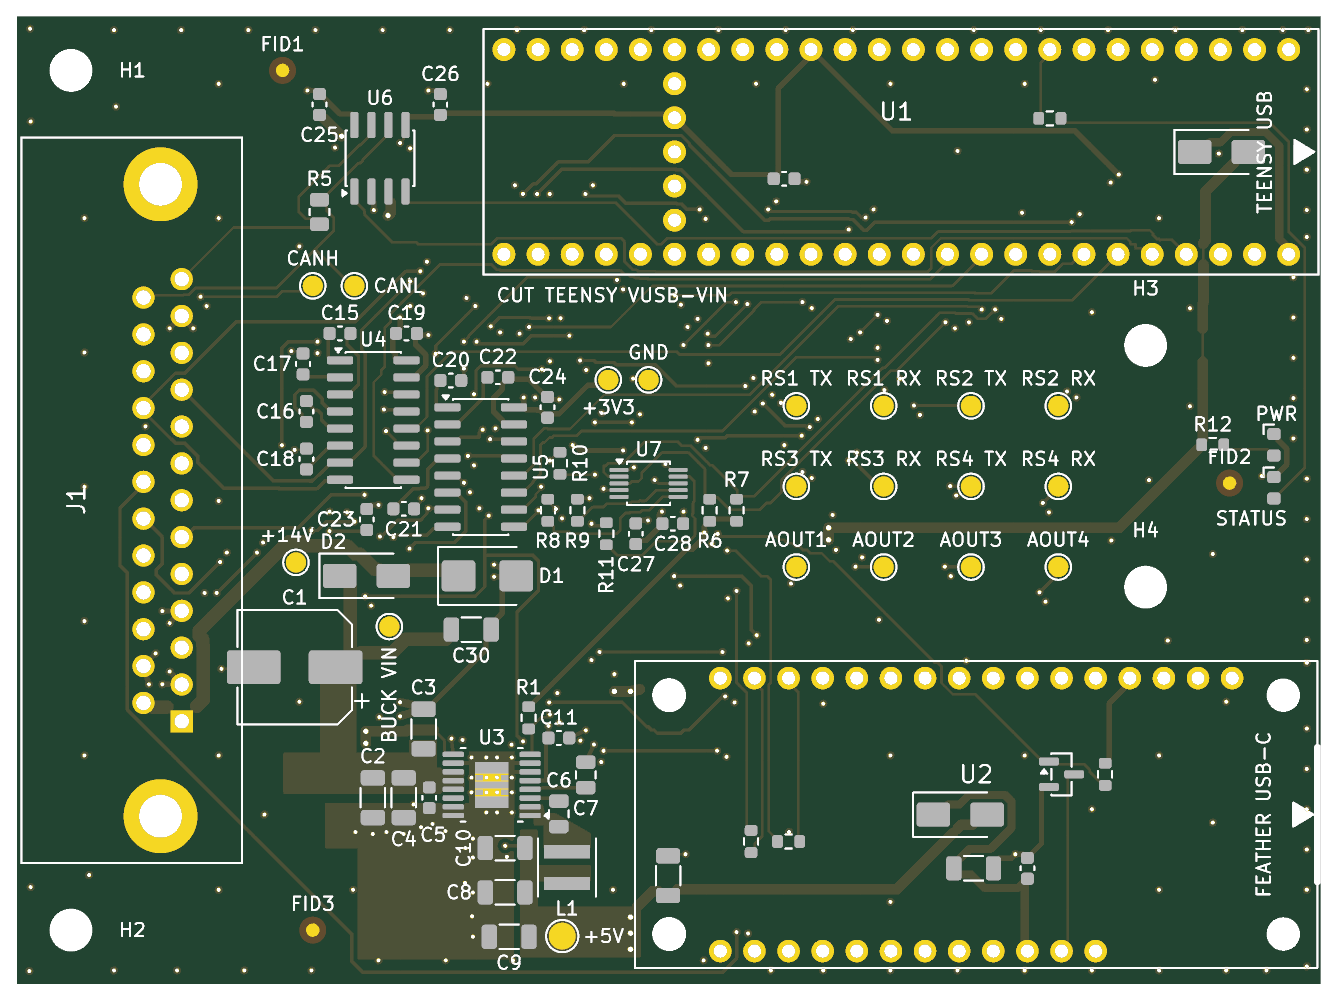
- Custom 4-layer board with a Teensy 4.1, an ESP32, and a single DB25 harness connector.
- RS-232, CAN, analog outputs, and microSD, in a parametric 3D-printed enclosure.
Software.
- C++ firmware that parses G3X and ECU data, flags stale values instead of freezing them, and logs to SD.
- Tablet cockpit page over the unit’s own WiFi, with automated tests and CI.