Hardware.
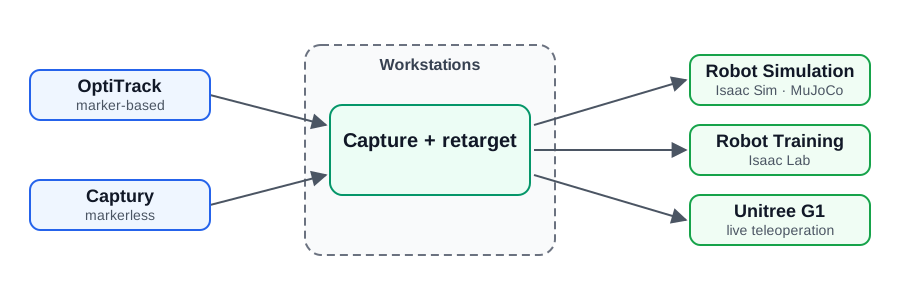
- Commissioned and configured two high-performance workstations for capture, simulation, and robot control.
- Set up marker-based (OptiTrack) and markerless (Captury) motion capture, and supervised live operation of a Unitree G1 humanoid.
Software.
- Motion capture to robot simulation: live capture retargeted onto a simulated humanoid in Isaac Sim and MuJoCo, with Isaac Lab for robot training.
- Motion capture to live teleoperation: capture driving the physical robot.